ADVANCED CERAMICS
The PLP substrate high-speed transfer robot is designed for automated transport of large substrates. It features a horizontal articulated arm and a dual-cantilever structure, and can be configured with end-effectors such as grippers, Bernoulli handlers, or vacuum suction. Equipment interfaces, substrate specifications, and system performance must be confirmed for the actual operating conditions.
Material: alumina; existing documentation specifies approximately 99% purity;
Name: PLP substrate high-speed transfer robot;
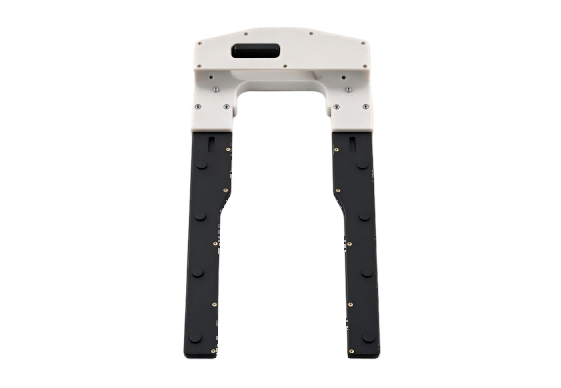
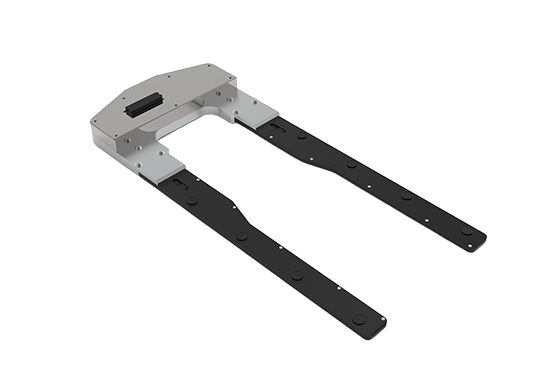
Structure: horizontal articulated arm, dual cantilever; top-fixed or bottom-fixed installation can be selected according to the equipment;
Capability range: existing documentation covers 600 mm × 600 mm workpieces and a reference payload of under 4 kg; actual specifications are subject to system confirmation;
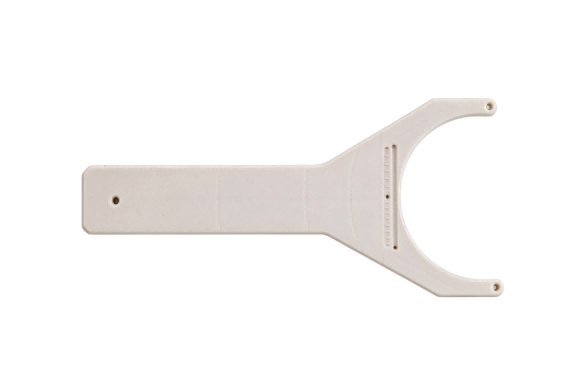
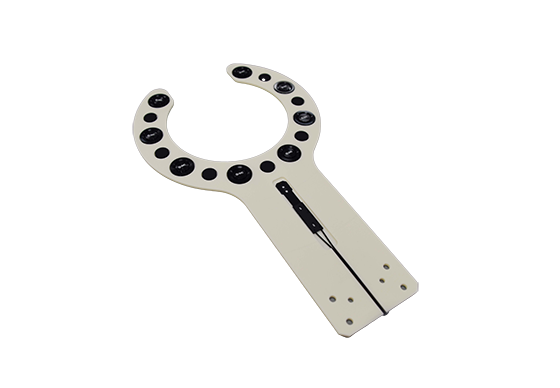
End-effector options: gripper lifting, contact/non-contact Bernoulli handling, vacuum suction, and custom U-shaped fingers can be evaluated.
Semiconductors: transfers PLP substrates between EFEMs, sorters, cleaning equipment, and optical inspection equipment.
Electronics manufacturing: transfers panels in dual-port or parallel-configuration equipment.
New energy: provides high-speed, stable substrate transport in atmospheric environments.
Medical/chemical: handles panels in clean environments; cleanliness and vibration requirements must be confirmed.
Optics: transports substrates and performs position calibration in inspection equipment.
The dual-cantilever structure helps provide high-speed, stable transport of large substrates. Actual vibration and cycle-time performance must be confirmed through testing of the complete system. Non-contact calibration can reduce the need for additional positioning mechanisms; the specific calibration accuracy and range of compatibility are subject to system validation. Multiple end-effector mounting options facilitate adaptation to different workpieces, equipment layouts, and process requirements.
When selecting a configuration, confirm the substrate dimensions and weight, arm mounting method, finger design, cycle time, stroke, payload, positioning accuracy, cleanliness, and vibration requirements.
For a quotation, please provide product drawings or sketches, critical dimensions and tolerances, material grade, operating temperature, load, process media, assembly method, surface requirements, quantity, and inspection standards. This information will help determine the material, structure, and manufacturing process.